Hi!
I develop perception and learning methods that help robots understand and interact with the physical world. My current research focuses on generalization in robot manipulation: how robots can apply what they learn to new objects, tasks, and environments. My work builds on a background in state estimation, visual odometry, representation learning, and geometric deep learning.
I’m currently a Postdoctoral Associate at the MIT Biomimetic Robotics Lab , working with Prof. Sangbae Kim . I received my Ph.D. and M.S. in Robotics from the University of Michigan, where I was advised by Prof. Maani Ghaffari , and my B.S. in Mechanical Engineering from National Taiwan University.
If you find any of my work interesting, feel free to reach out to me at tzuyuan at mit dot edu. I’m happy to chat!
News Research For a complete and current record, please visit my Google Scholar profile .
* denotes equal contribution.
Open the video directly. Point2Pose: Occlusion-Recovering 6D Pose Tracking and 3D Reconstruction for Multiple Unknown Objects Via 2D Point Trackers Tzu-Yuan Lin , Ho Jae Lee, Kevin Doherty, Yonghyeon Lee, Sangbae KimEuropean Conference on Computer Vision (ECCV), 2026
Open the video directly. See to Reach, Feel to Grasp: Learning A Blind Grasp Reflex for Anthropomorphic Robotic Hands Alexander Alexiev, Tzu-Yuan Lin , Sang Min Kim, Ho Jae Lee, Yonghyeon Lee, Sangbae Kim arXiv, 2026
Open the video directly. Real-Time Force Regulation for Whole-Hand Dexterous Grasping Sang Min Kim, Alexander Alexiev, Tzu-Yuan Lin , Sangbae Kim, Young Min Kim, Yonghyeon Lee arXiv, 2026
Open the video directly. Learning Reactive Dexterous Grasping via Hierarchical Task-Space RL Planning and Joint-Space QP Control Ho Jae Lee, Yonghyeon Lee, Alexander Alexiev, Tzu-Yuan Lin , Se Hwan Jeon, Sangbae Kim arXiv, 2026
Open the video directly. Hierarchical Reactive Grasping via Task-Space Velocity Fields and Joint-Space Quadratic Programming Yonghyeon Lee*, Tzu-Yuan Lin *, Alexander Alexiev, Sangbae Kim IEEE International Conference on Robotics and Automation (ICRA), 2026
Open the video directly. High-Bandwidth Tactile-Reactive Control for Grasp Adjustment Yonghyeon Lee*, Tzu-Yuan Lin *, Alexander Alexiev, Sangbae Kim IEEE International Conference on Robotics and Automation (ICRA), 2026
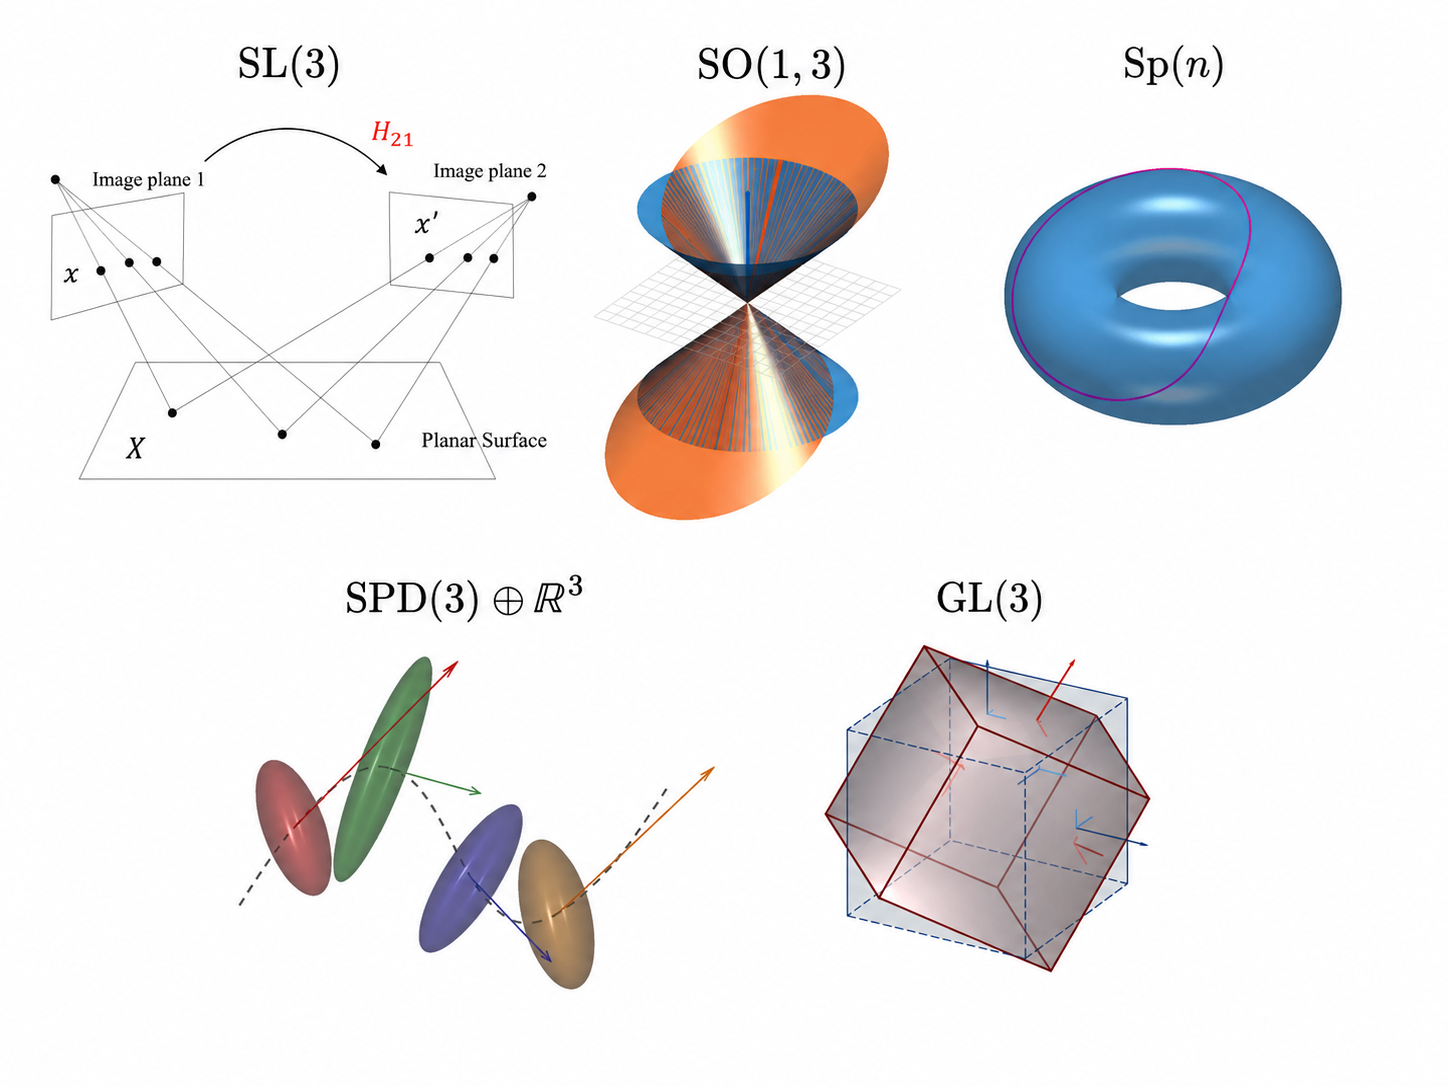
Equivariant Neural Networks for General Linear Symmetries on Lie Algebras Chankyo Kim*, Sicheng Zhao*, Minghan Zhu, Tzu-Yuan Lin , Maani Ghaffari International Conference on Machine Learning (ICML), 2026
A Survey of Legged Robotics in Non-Inertial Environments: Past, Present, and Future I-Chia Chang, Xinyan Huang, Tzu-Yuan Lin , Sangli Teng, Wenjing Li, Maani Ghaffari, Jingang Yi, Yan Gu arXiv, 2026
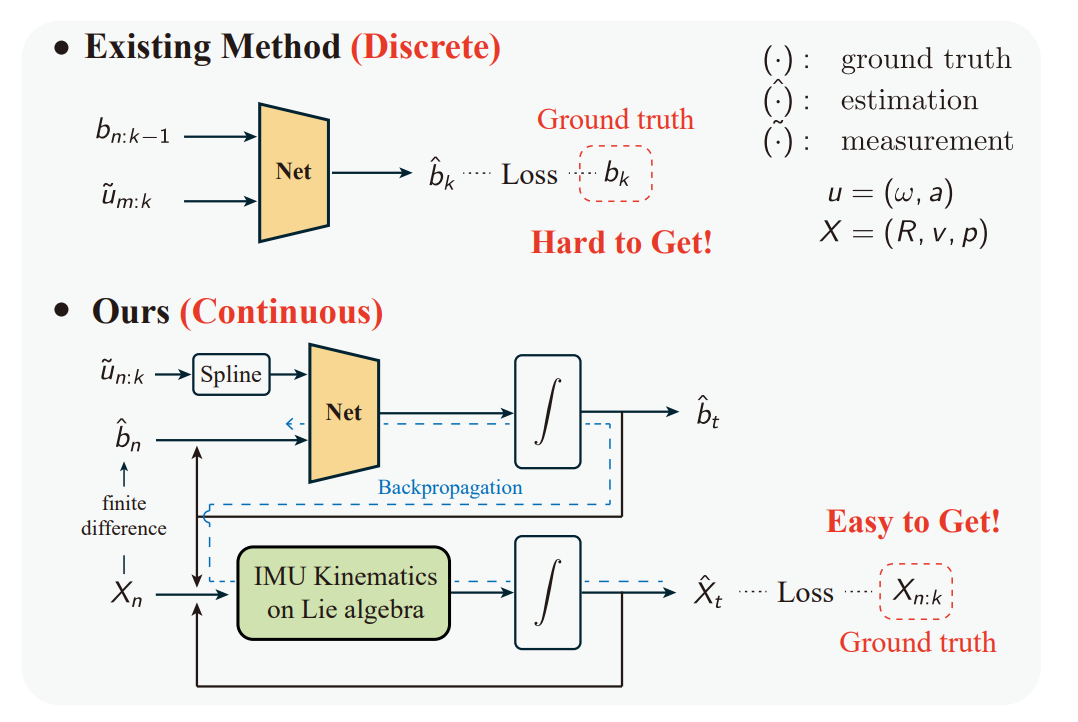
Debiasing 6-DOF IMU via Hierarchical Learning of Continuous Bias Dynamics Ben Liu, Tzu-Yuan Lin , Wei Zhang, Maani Ghaffari Robotics: Science and Systems (RSS), 2025
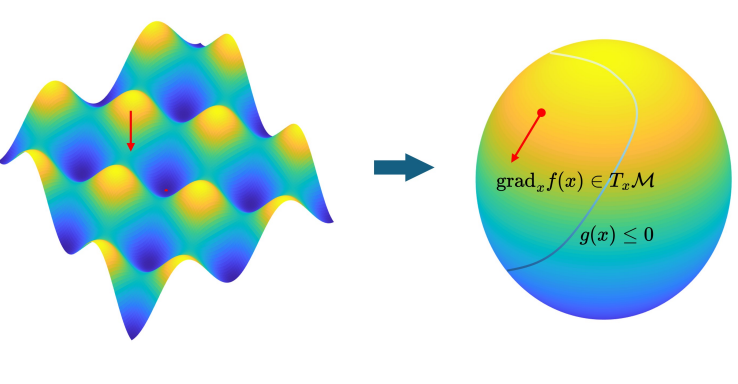
Riemannian Direct Trajectory Optimization of Rigid Bodies on Matrix Lie Groups Sangli Teng, Tzu-Yuan Lin , William A Clark, Ram Vasudevan, Maani Ghaffari Robotics: Science and Systems (RSS), 2025
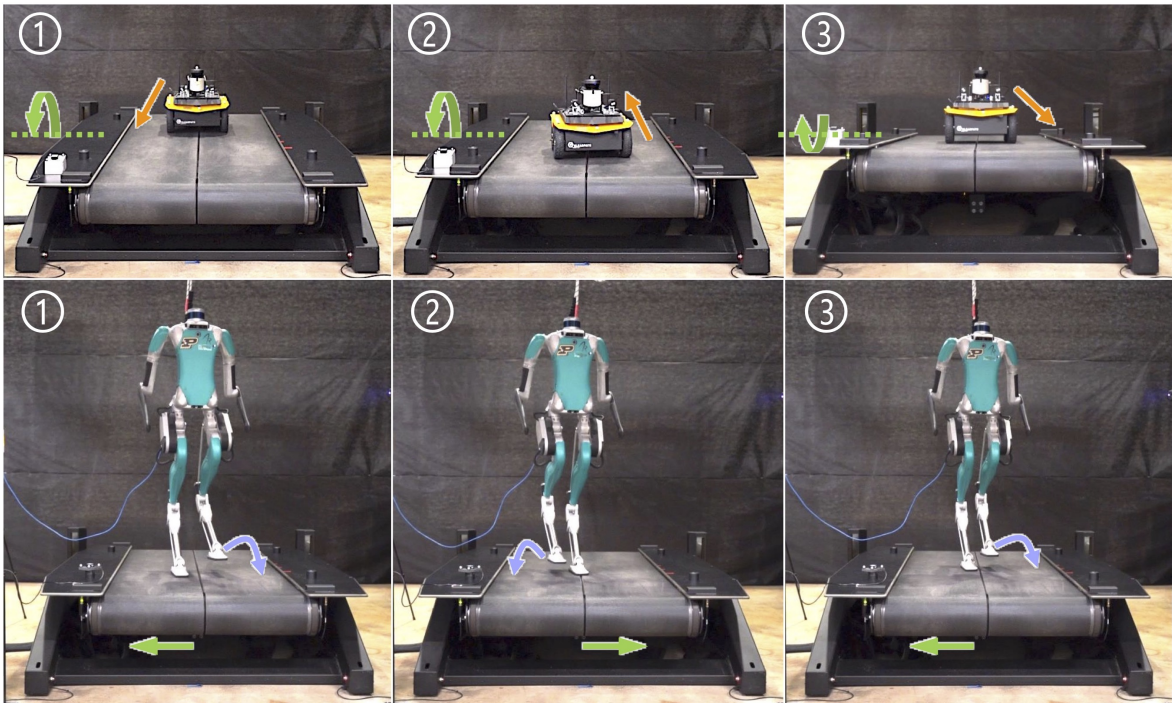
Invariant Filtering for Full-State Estimation of Ground Robots in Non-Inertial Environments Zijian He, Sangli Teng, Tzu-Yuan Lin , Maani Ghaffari, Yan Gu IEEE/ASME Transactions on Mechatronics, 2025
Open the video directly. Proprioceptive Invariant Robot State Estimation Tzu-Yuan Lin , Tingjun Li, Wenzhe Tong, and Maani GhaffariarXiv, 2025
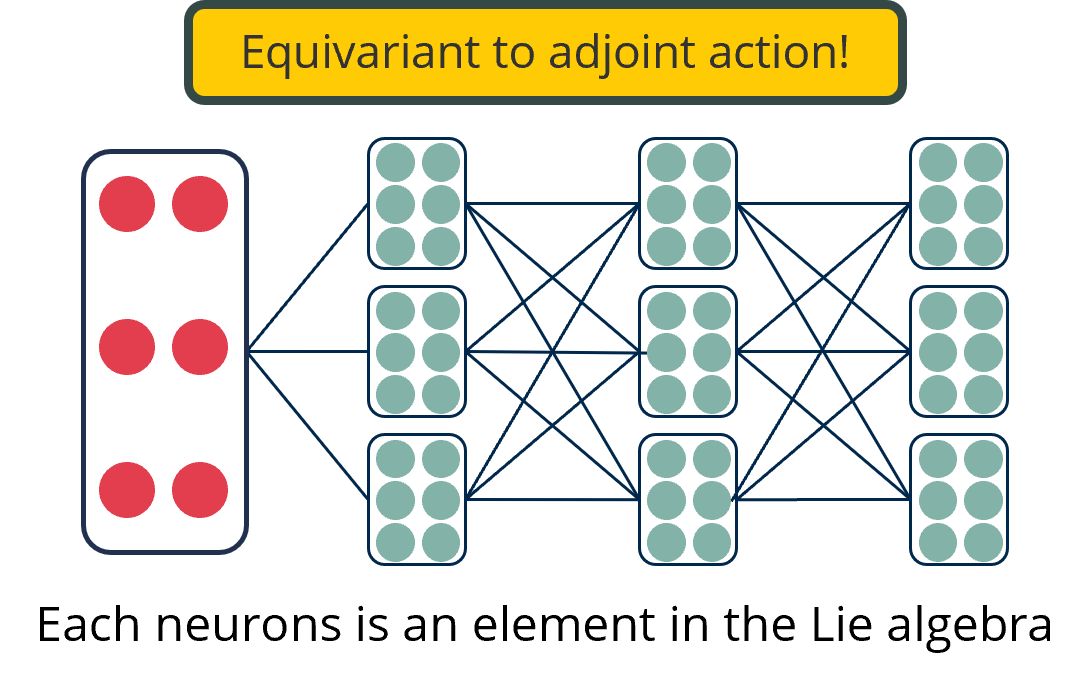
Lie Neurons: Adjoint-Equivariant Neural Networks for Semisimple Lie Algebras Tzu-Yuan Lin *, Minghan Zhu*, and Maani GhaffariInternational Conference on Machine Learning (ICML), 2024
Legged Robot State Estimation using Invariant Kalman Filtering and Learned Contact Events Tzu-Yuan Lin , Ray Zhang, Justin Yu, and Maani GhaffariConference on Robot Learning (CoRL), 2021
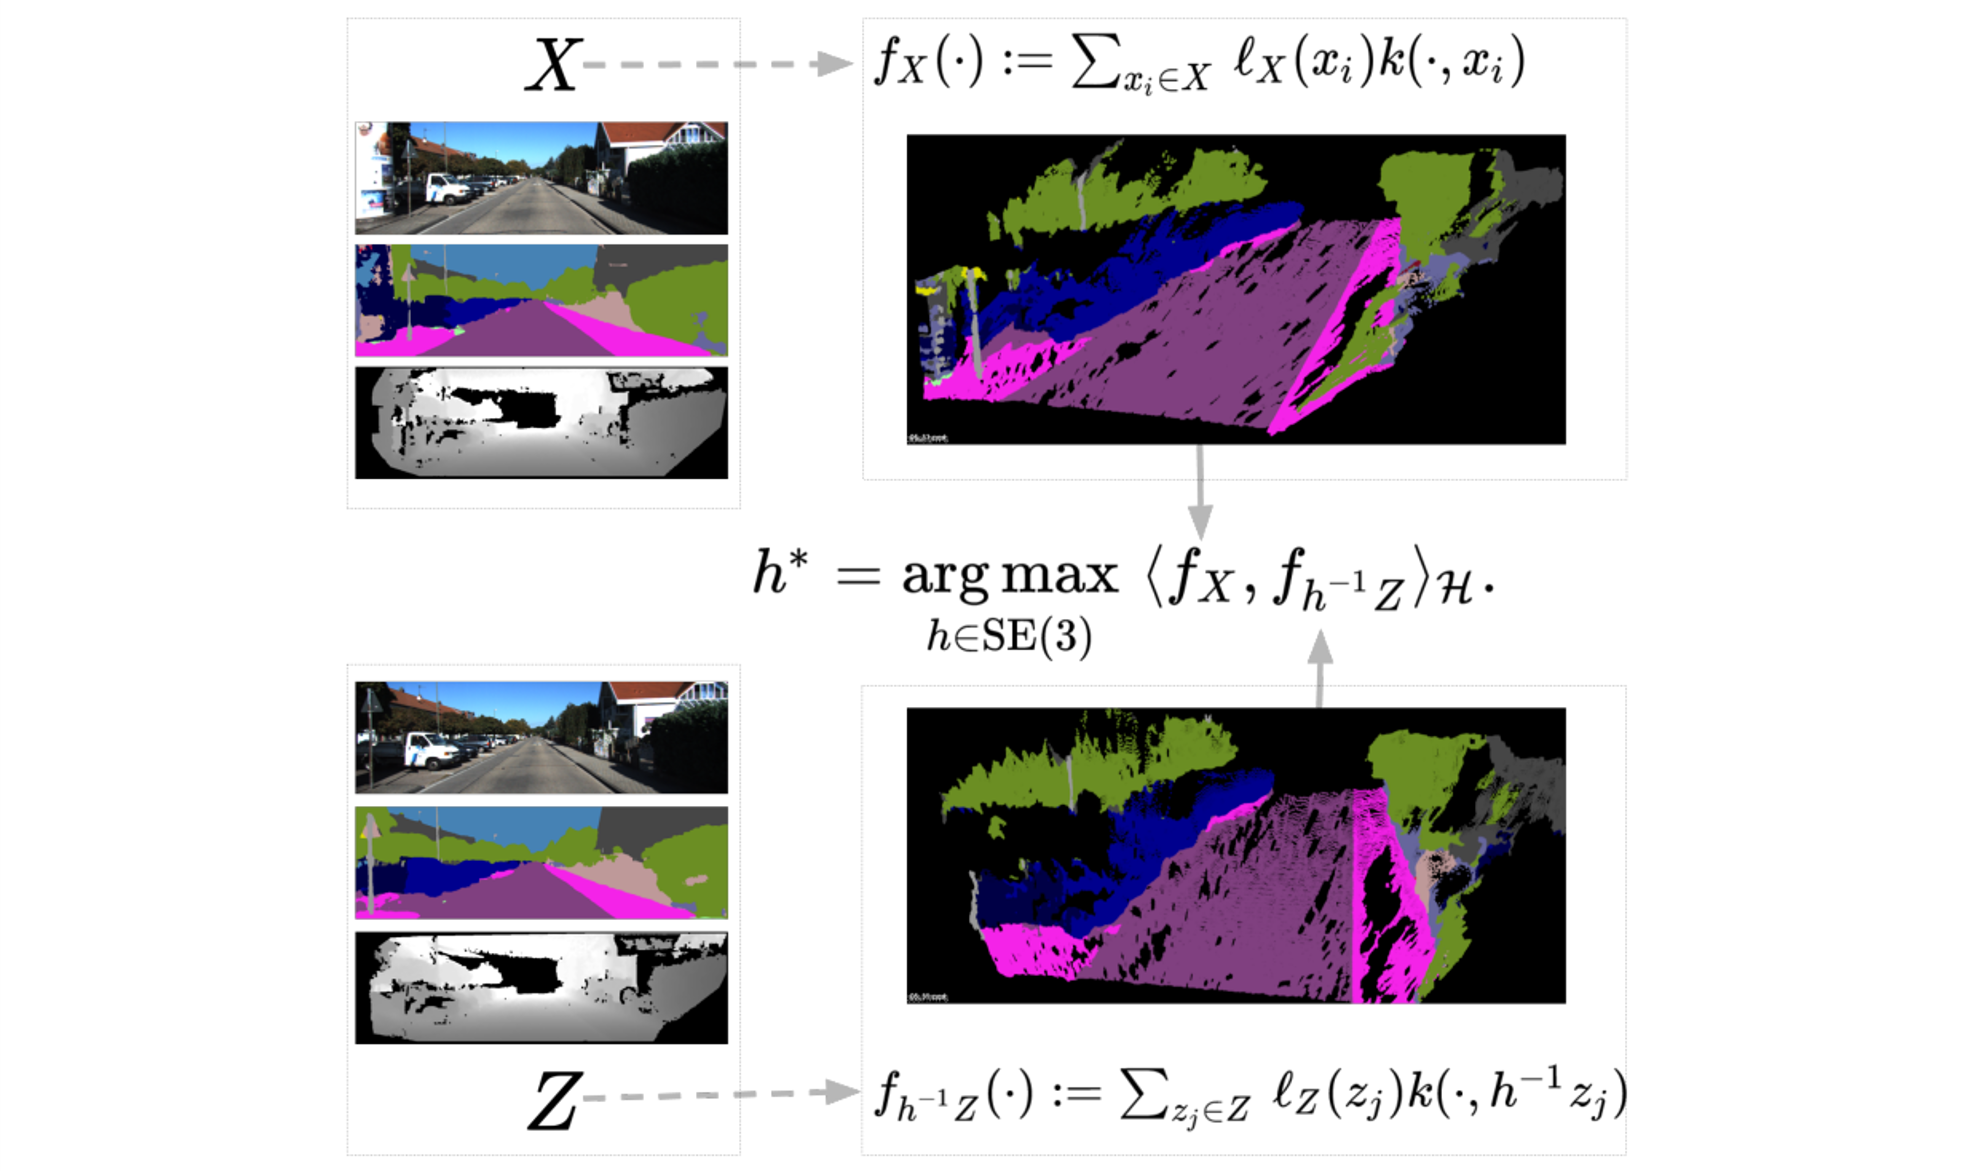
A New Framework for Registration of Semantic Point Clouds from Stereo and RGB-D Cameras Ray Zhang, Tzu-Yuan Lin , Chien Erh Lin, Steven A. Parkison, William Clark, Jessy W. Grizzle, Ryan M. Eustice, Maani Ghaffari IEEE International Conference on Robotics and Automation (ICRA), 2021