Selected publications are listed below. For a complete and current record, visit my Google Scholar profile.
* denotes equal contribution.
| | Point2Pose: Occlusion-Recovering 6D Pose Tracking and 3D Reconstruction for Multiple Unknown Objects Via 2D Point TrackersTzu-Yuan Lin, Ho Jae Lee, Kevin Doherty, Yonghyeon Lee, Sangbae KimEuropean Conference on Computer Vision (ECCV), 2026 |
| | See to Reach, Feel to Grasp: Learning A Blind Grasp Reflex for Anthropomorphic Robotic HandsAlexander Alexiev, Tzu-Yuan Lin, Sang Min Kim, Ho Jae Lee, Yonghyeon Lee, Sangbae KimarXiv, 2026 |
| | Real-Time Force Regulation for Whole-Hand Dexterous GraspingSang Min Kim, Alexander Alexiev, Tzu-Yuan Lin, Sangbae Kim, Young Min Kim, Yonghyeon LeearXiv, 2026 |
| | Learning Reactive Dexterous Grasping via Hierarchical Task-Space RL Planning and Joint-Space QP ControlHo Jae Lee, Yonghyeon Lee, Alexander Alexiev, Tzu-Yuan Lin, Se Hwan Jeon, Sangbae KimarXiv, 2026 |
| | Hierarchical Reactive Grasping via Task-Space Velocity Fields and Joint-Space Quadratic ProgrammingYonghyeon Lee*, Tzu-Yuan Lin*, Alexander Alexiev, Sangbae KimIEEE International Conference on Robotics and Automation (ICRA), 2026 |
| | High-Bandwidth Tactile-Reactive Control for Grasp AdjustmentYonghyeon Lee*, Tzu-Yuan Lin*, Alexander Alexiev, Sangbae KimIEEE International Conference on Robotics and Automation (ICRA), 2026 |
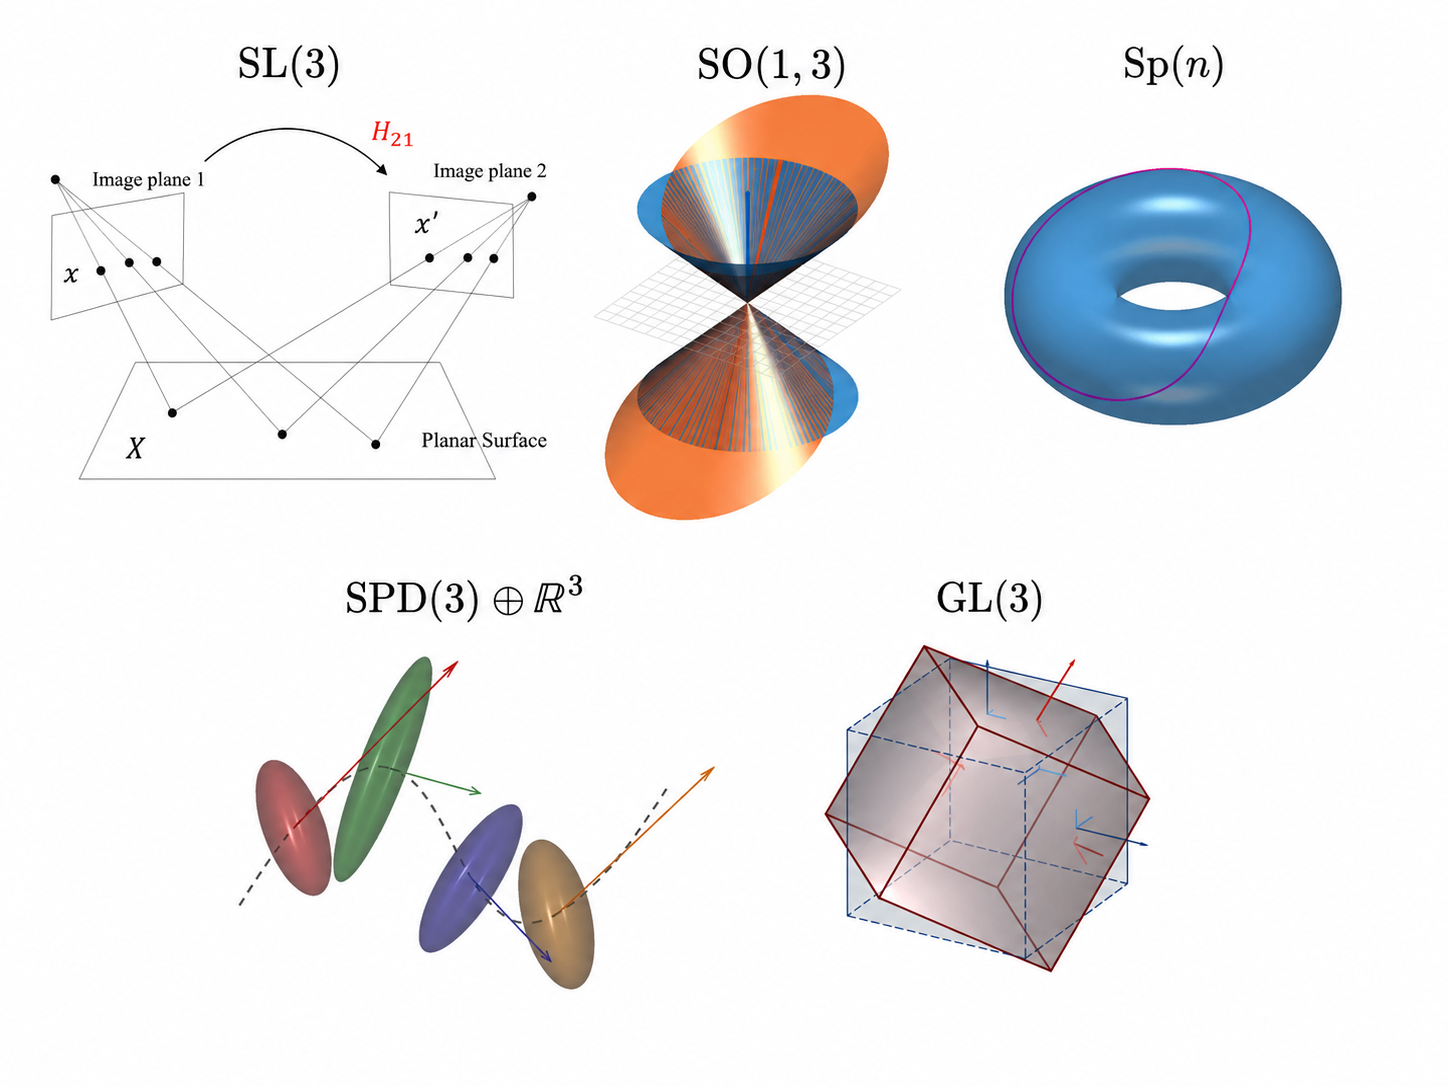 | Equivariant Neural Networks for General Linear Symmetries on Lie AlgebrasChankyo Kim*, Sicheng Zhao*, Minghan Zhu, Tzu-Yuan Lin, Maani GhaffariInternational Conference on Machine Learning (ICML), 2026 |
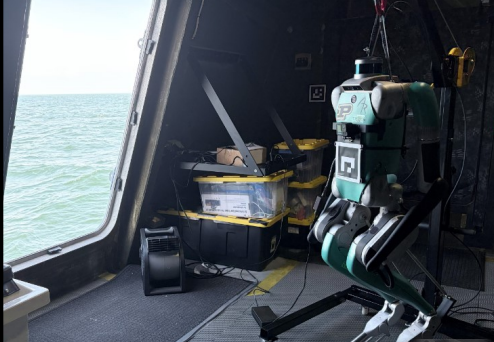 | A Survey of Legged Robotics in Non-Inertial Environments: Past, Present, and FutureI-Chia Chang, Xinyan Huang, Tzu-Yuan Lin, Sangli Teng, Wenjing Li, Maani Ghaffari, Jingang Yi, Yan GuarXiv, 2026 |
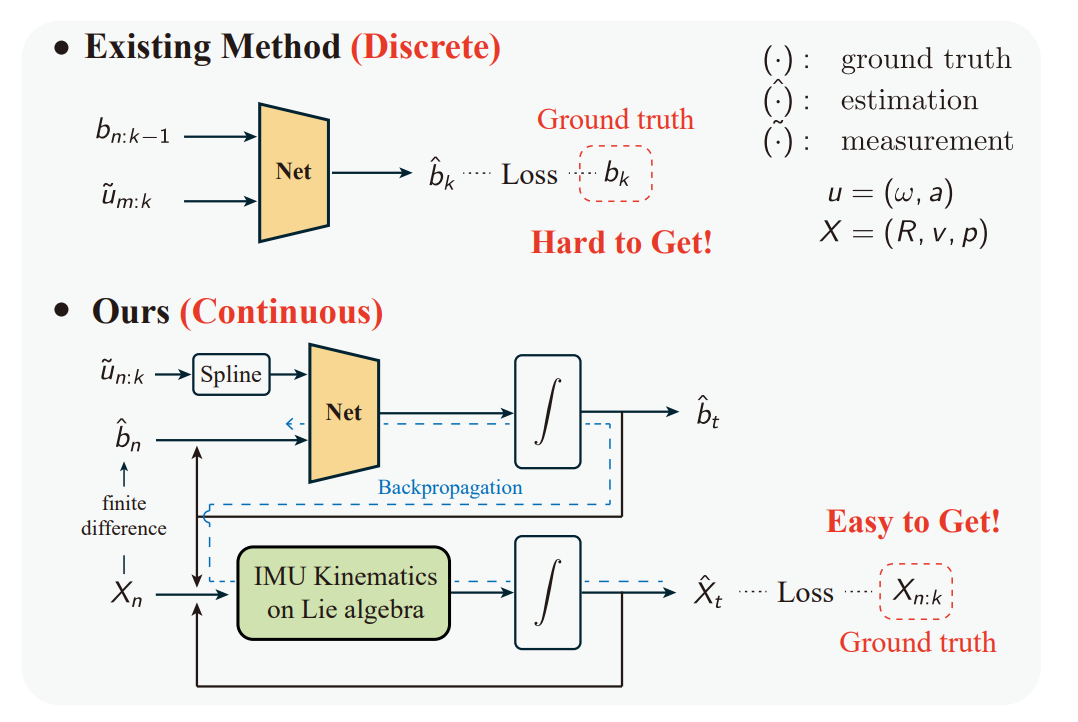 | Debiasing 6-DOF IMU via Hierarchical Learning of Continuous Bias DynamicsBen Liu, Tzu-Yuan Lin, Wei Zhang, Maani GhaffariRobotics: Science and Systems (RSS), 2025 |
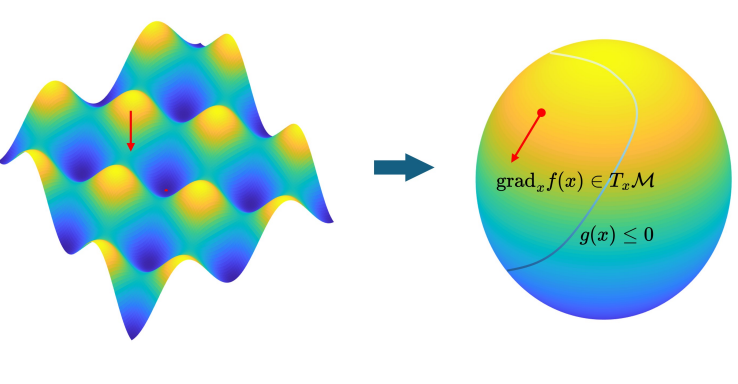 | Riemannian Direct Trajectory Optimization of Rigid Bodies on Matrix Lie GroupsSangli Teng, Tzu-Yuan Lin, William A Clark, Ram Vasudevan, Maani GhaffariRobotics: Science and Systems (RSS), 2025 |
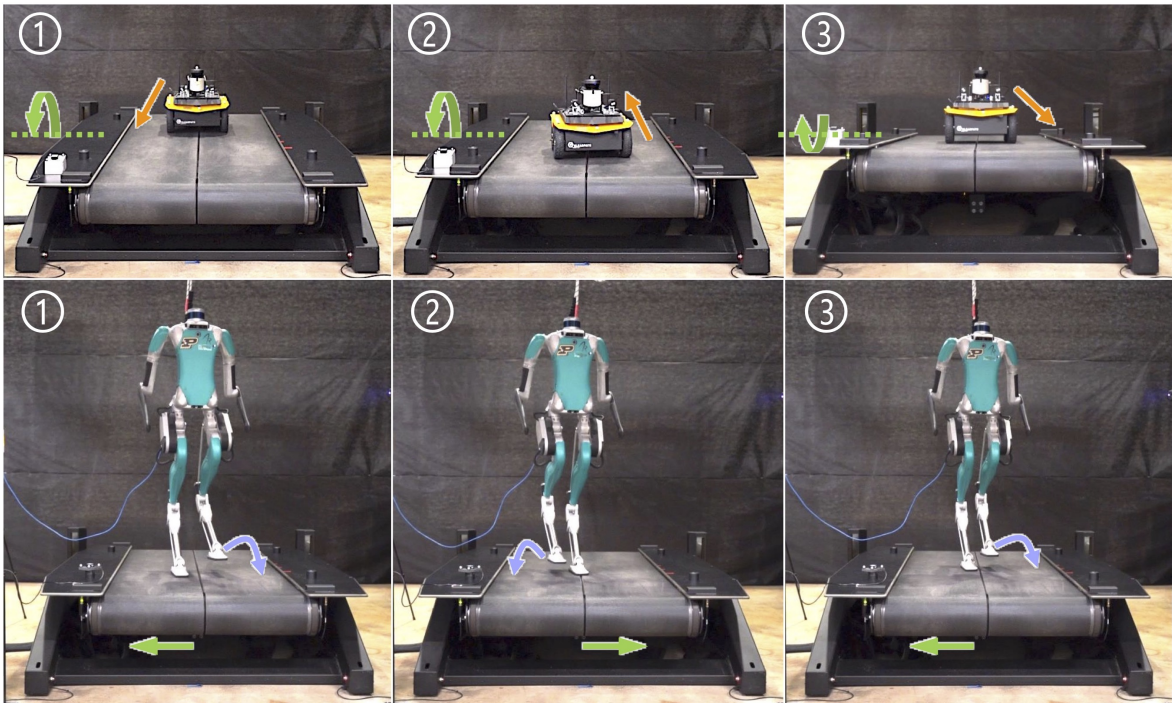 | Invariant Filtering for Full-State Estimation of Ground Robots in Non-Inertial EnvironmentsZijian He, Sangli Teng, Tzu-Yuan Lin, Maani Ghaffari, Yan GuIEEE/ASME Transactions on Mechatronics, 2025 |
| | Proprioceptive Invariant Robot State EstimationTzu-Yuan Lin, Tingjun Li, Wenzhe Tong, and Maani GhaffariarXiv, 2025 |
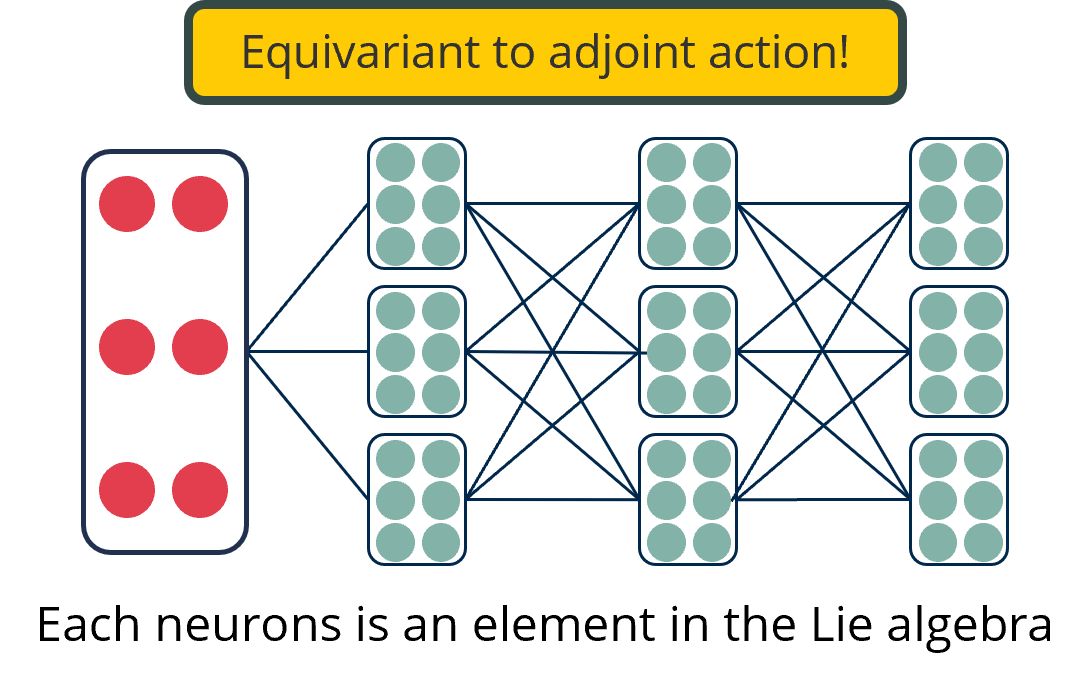 | Lie Neurons: Adjoint-Equivariant Neural Networks for Semisimple Lie AlgebrasTzu-Yuan Lin*, Minghan Zhu*, and Maani GhaffariInternational Conference on Machine Learning (ICML), 2024 |
 | Legged Robot State Estimation using Invariant Kalman Filtering and Learned Contact EventsTzu-Yuan Lin, Ray Zhang, Justin Yu, and Maani GhaffariConference on Robot Learning (CoRL), 2021 |
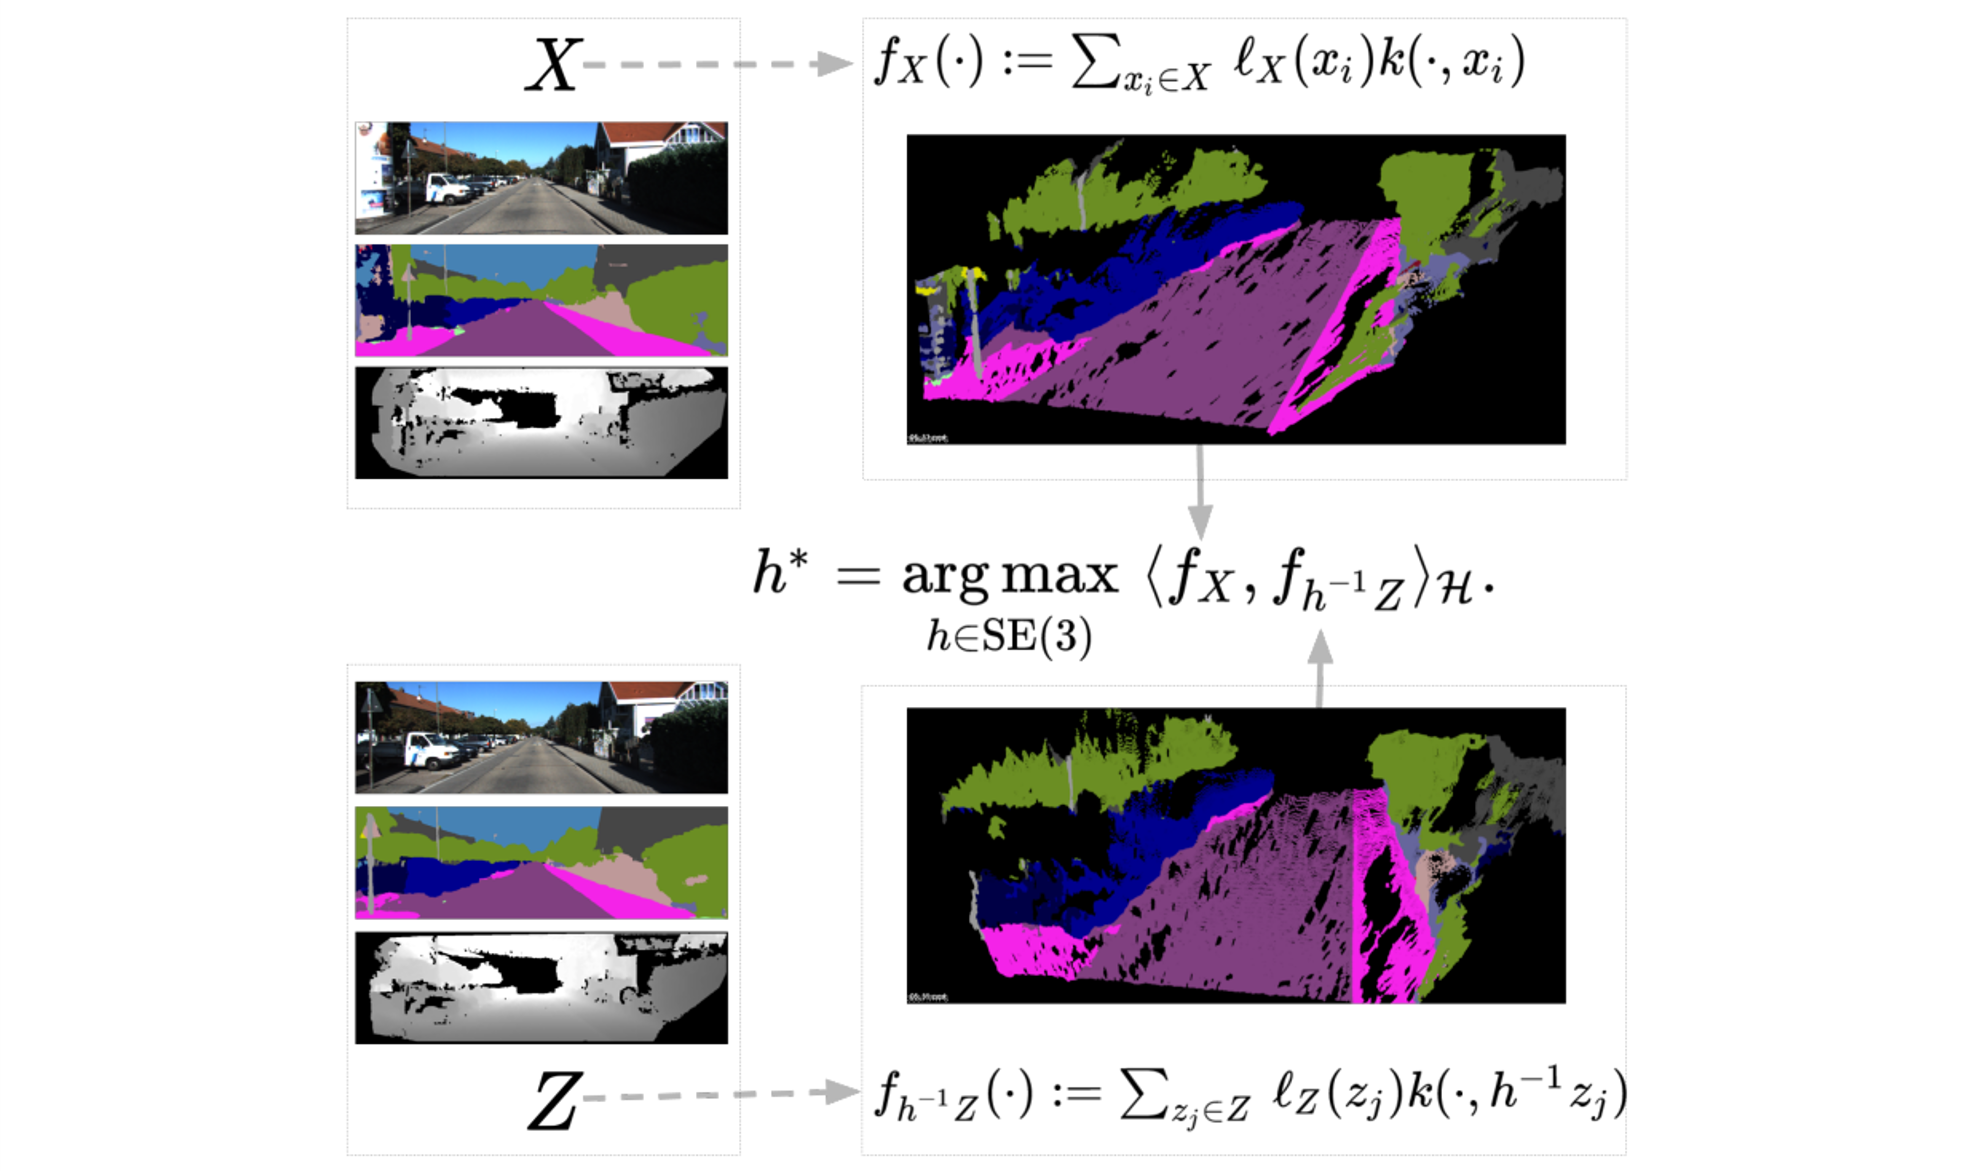 | A New Framework for Registration of Semantic Point Clouds from Stereo and RGB-D CamerasRay Zhang, Tzu-Yuan Lin, Chien Erh Lin, Steven A. Parkison, William Clark, Jessy W. Grizzle, Ryan M. Eustice, Maani GhaffariIEEE International Conference on Robotics and Automation (ICRA), 2021 |